K-Startup Maker Project 2020
Maker project supported by the Korean government (K-Startup)
- Date
- Jul 2020 – Dec 2020
- Tags
Project Description
This is one of the Maker projects supported by the Ministry of SMEs and Startups of South Korea, which encourage creative work that uses digital devices and various tools to bring ideas to life. The program is open to everyone from high school and university students to working professionals.
Details
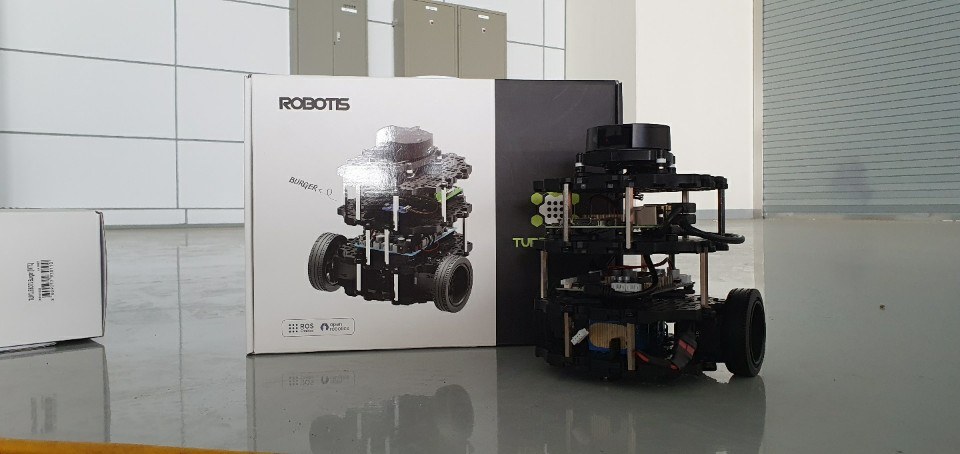
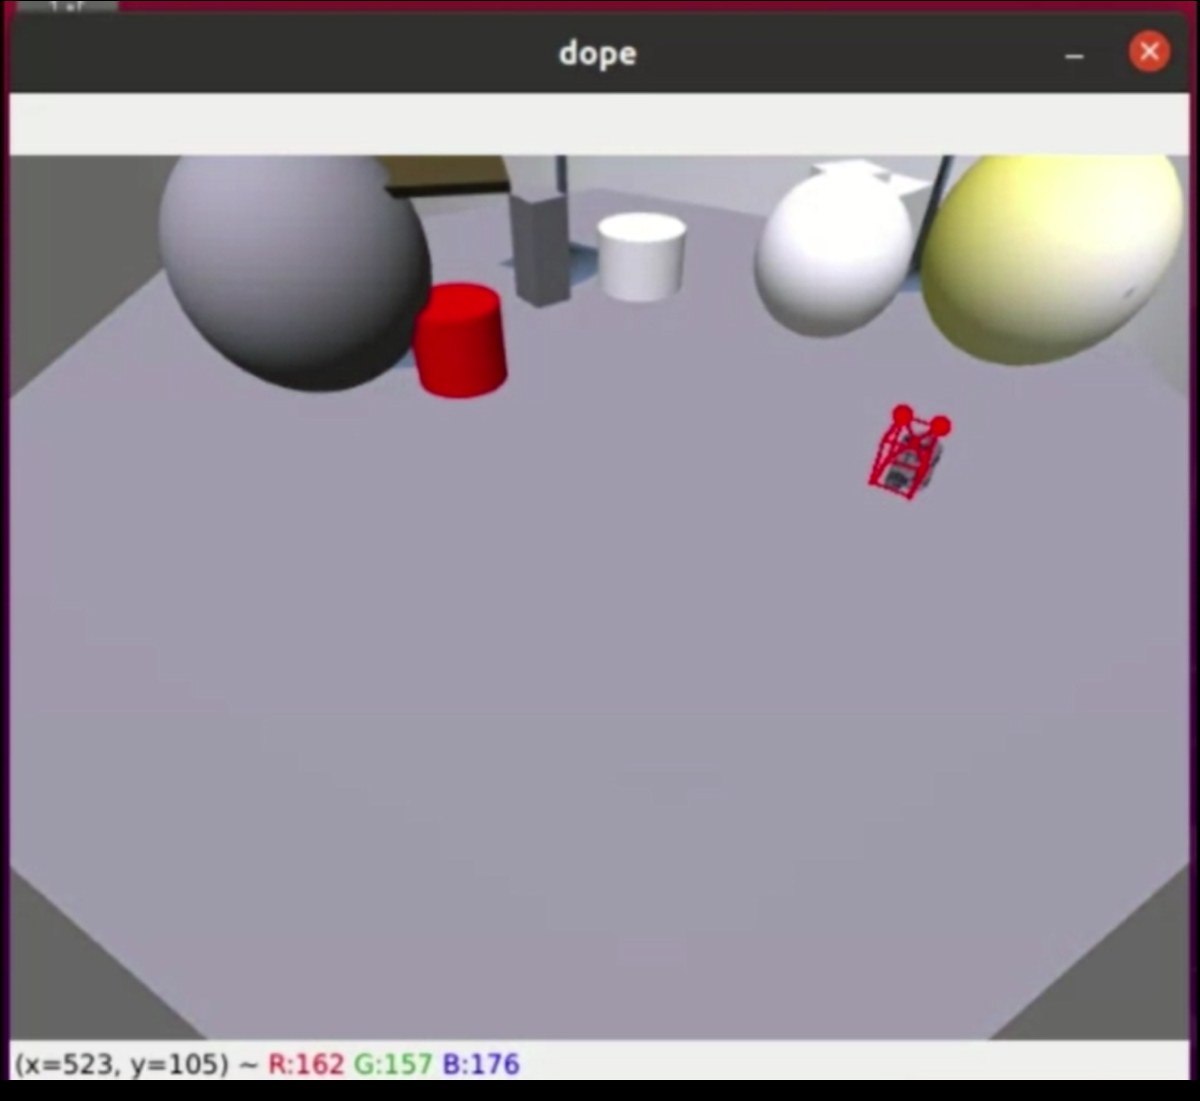
The goal of this project was to control a robot without attaching any sensors to it other than its actuators. We set this goal because the many sensors typically mounted on robots raise production costs, making it harder for robots to be widely adopted in society. To control the robot, we installed multiple external cameras and performed driving-area detection with U-Net and robot pose detection with DOPE. To generate training data, we built a ROS Gazebo simulation environment and then applied the trained models in a real-world setting. I served as the overall team leader, and we used TurtleBot as our robot platform. (GitHub)
Remarks
This project was carried out with a grant of $5,000. The same work was also conducted as the X-Corps Project 2020.
Images